|
Ni Chaojun | 倪超骏
Hi! I'm Chaojun Ni, a Master's student at the Complex Network Systems Lab, College of Engineering, Peking University, under the supervision of Assistant Professor Wenjun Mei.
From my senior undergraduate year through my second year of graduate school, I have been interning at GigaAI, where my corporate mentor is Zheng Zhu. Before joining Peking University, I completed my undergraduate studies in Computer Science and Technology at Jiangxi University of Finance and Economics, where I was advised by Prof. Yuming Fang.
My primary research interests lie in 🚗 autonomous driving, 🏗️ 3D reconstruction, and 🌍 world models. Additionally, I enjoy working on exciting engineering projects and participating in algorithm competitions such as Kaggle and Codeforces.
Email |
GitHub
|
📰 News
[Jul 2026]
ECCV 2026
🎉 ReconDreamer-RL has also been accepted to ECCV 2026!
[Mar 2025]
CVPR 2025
🎉 SwiftVLA has been accepted to CVPR 2025!
[Mar 2025]
NEW
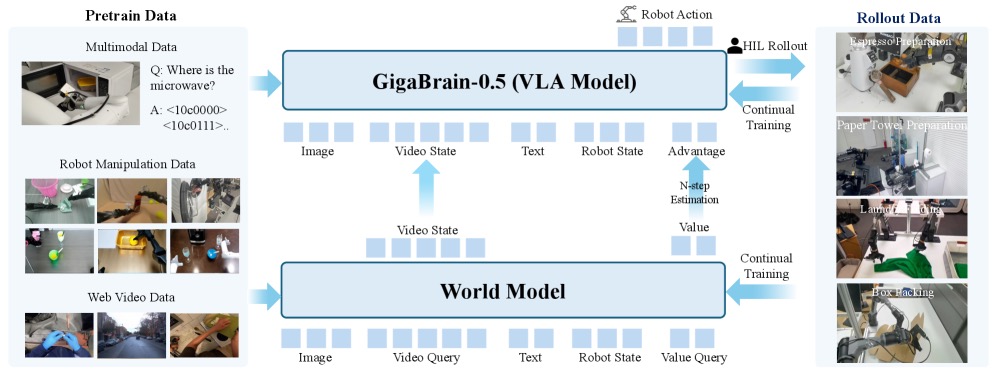
Excited to release GigaBrain-0.5M: a VLA that learns from world model-based reinforcement learning!
|
📑 Publications
CVPR 2025
|
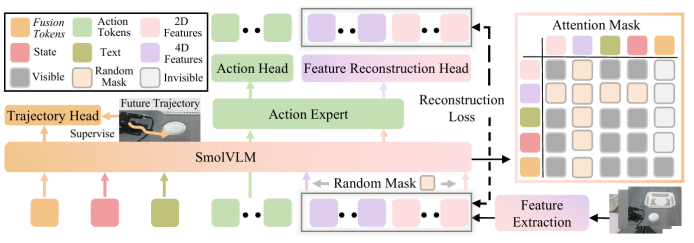
SwiftVLA:
Unlocking Spatiotemporal Dynamics for Lightweight VLA Models at Minimal Overhead
Chaojun Ni, Cheng Chen, Xiaofeng Wang, Zheng Zhu, Boyuan Wang, Tianrun Chen, Guosheng Zhao, Haoyun Li, Zhehao Dong, Qiang Zhang, Yun Ye, Guan Huang, Wenjun Mei
[Project]
[Paper]
SwiftVLA enhances lightweight Vision–Language–Action models with efficient 4D spatiotemporal understanding, offering exceptional performance on Orin edge devices with significantly reduced latency and memory usage.
|
ECCV 2026
|
GigaWorld-Policy:
An Efficient Action-Centered World–Action Model
Chaojun Ni, Xinyu Zhou, Yukun Zhou, Jingyu Liu, Xiaofeng Wang, Zheng Zhu, Yang Wang, Qiuping Deng, Yun Ye, Hao Li, Zhichao Liu, Jindi Lv, Boyuan Wang, Guosheng Zhao, Guan Huang, Min Cao, Wenjun Mei
[Project]
[Paper]
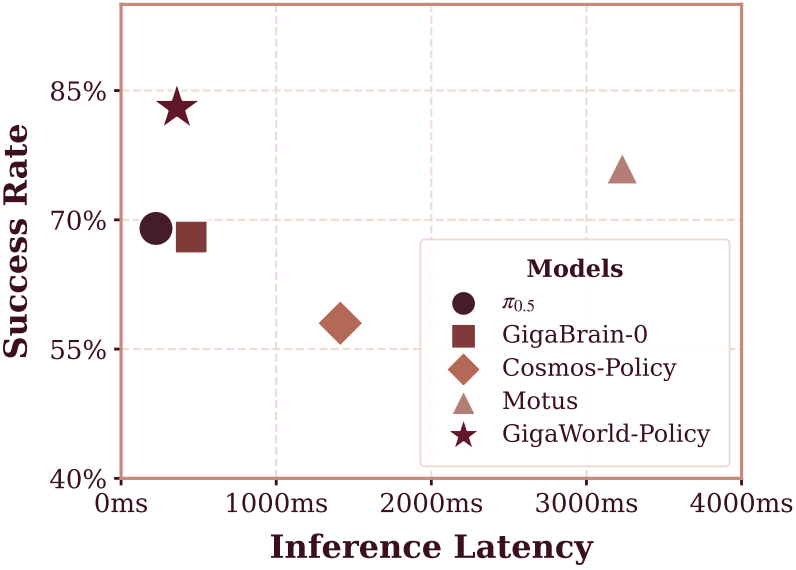
GigaWorld-Policy is an action-centered World–Action Model (WAM) that learns 2D pixel–action dynamics with optional video generation. It runs 9× faster than the leading WAM baseline Motus, improves task success rates by 7%, and outperforms π0.5 by 95% on RoboTwin 2.0.
|
Thesis 2024
|
The Intelligent Chess Control System Based on Planar Constraint Conditions
Chaojun Ni, Wenhui Jiang, Yuming Fang
🏆 Top Ten Undergraduate Thesis (2/10), JUFE
🏆 Outstanding Thesis (1/5), School of Information Management
[Paper]
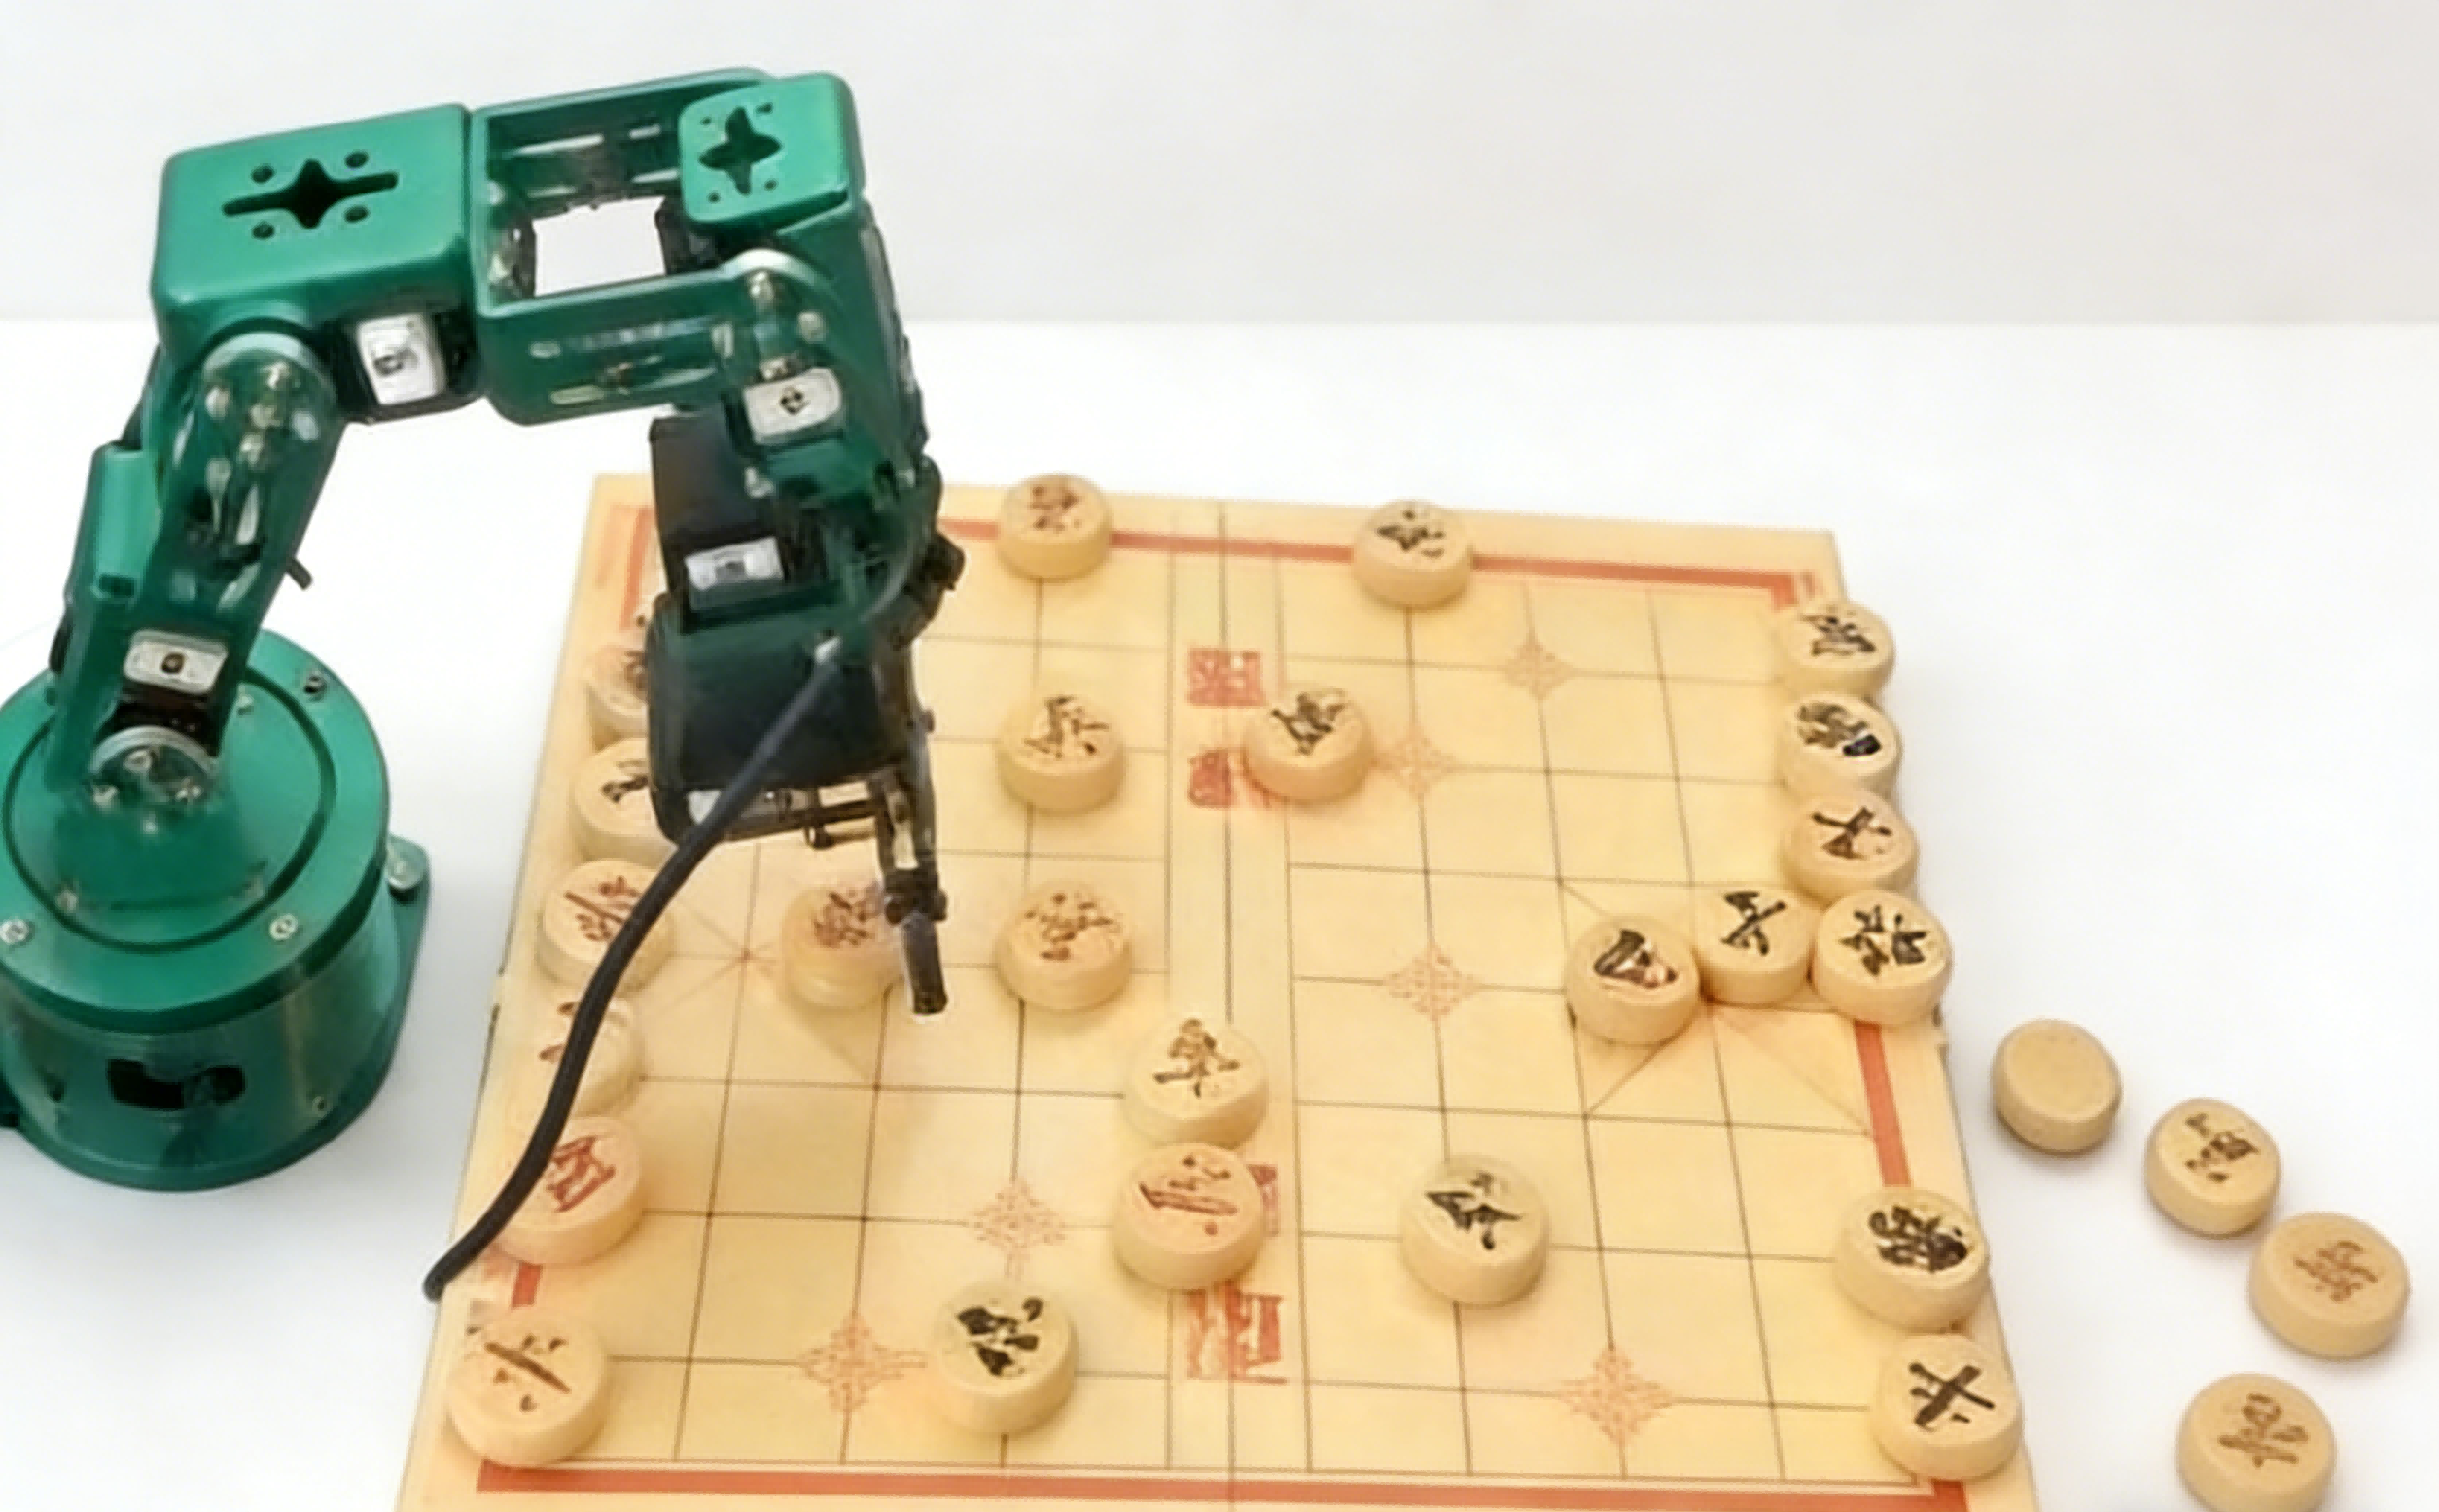
A human-machine gaming system developed at low cost using Raspberry Pi, robotic arm, and camera, involving lightweight target detection models and gaming algorithms.
|
|
🧾 Preprints
arXiv 2025
|
WonderFree: Enhancing Novel View Quality and Cross-View Consistency for 3D Scene Exploration
Chaojun Ni, Jie Li, Haoyun Li, Hengyu Liu, Xiaofeng Wang, Zheng Zhu, Guosheng Zhao, Boyuan Wang, Chenxin Li, Guan Huang, Wenjun Mei
[Project] [Paper]
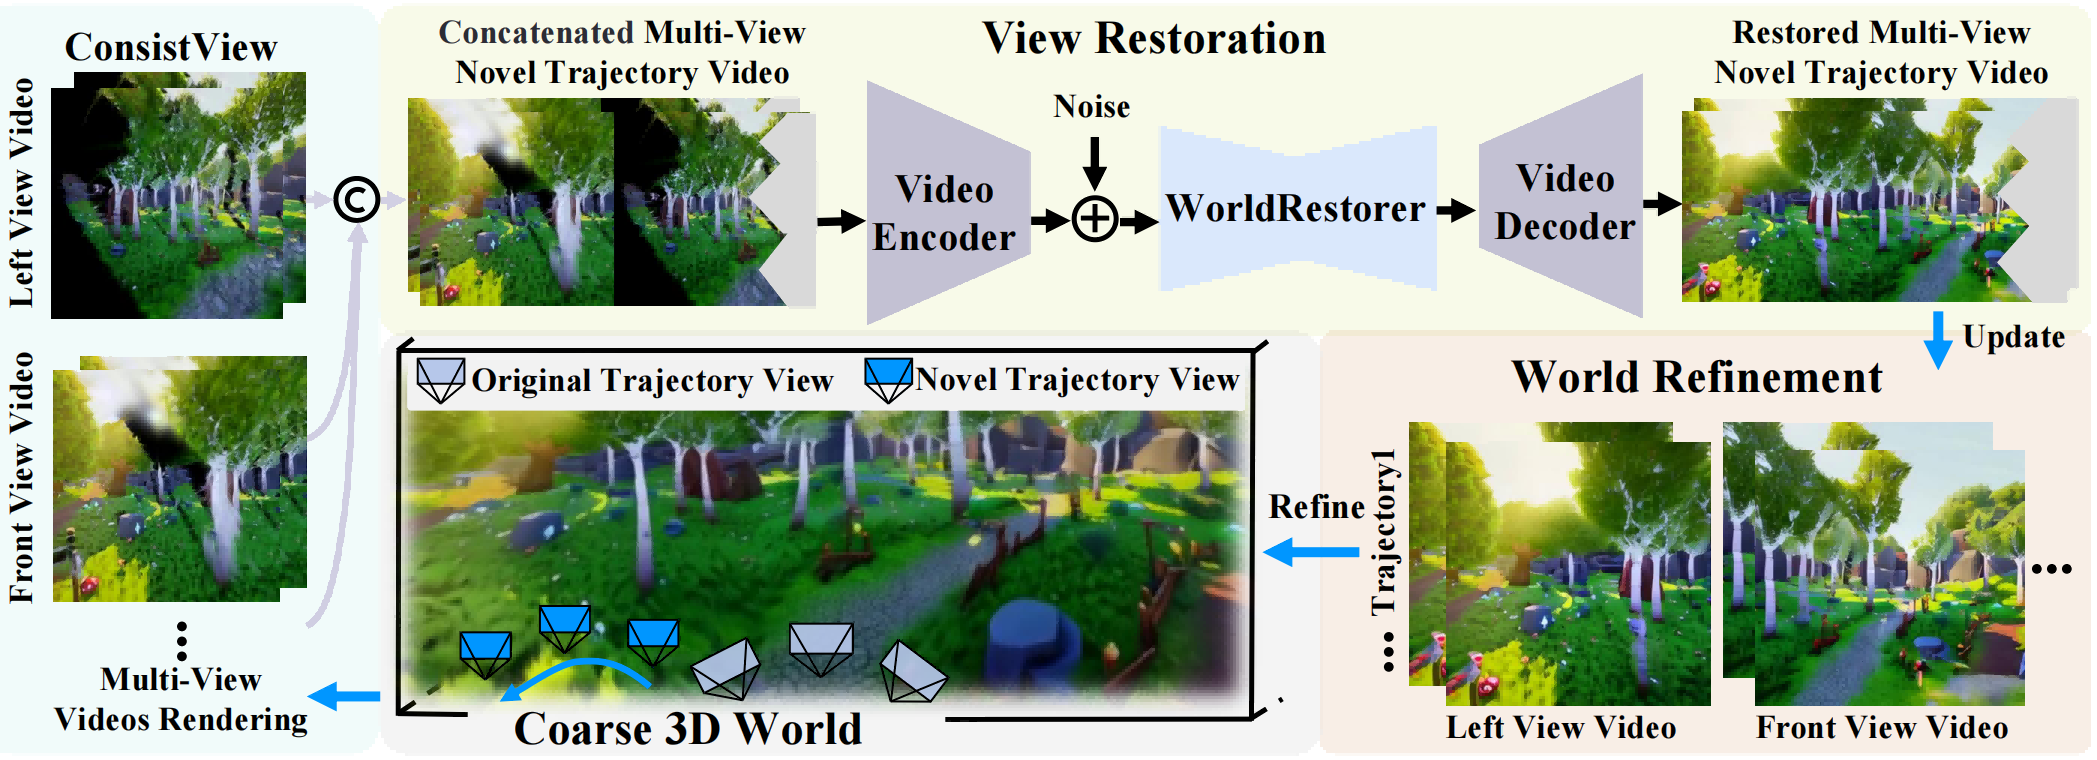
WonderFree proposes a method to enhance novel view synthesis quality and cross-view consistency, providing an improved experience in 3D scene exploration with enhanced realism and detail.
|
arXiv 2025
|
WonderTurbo++:
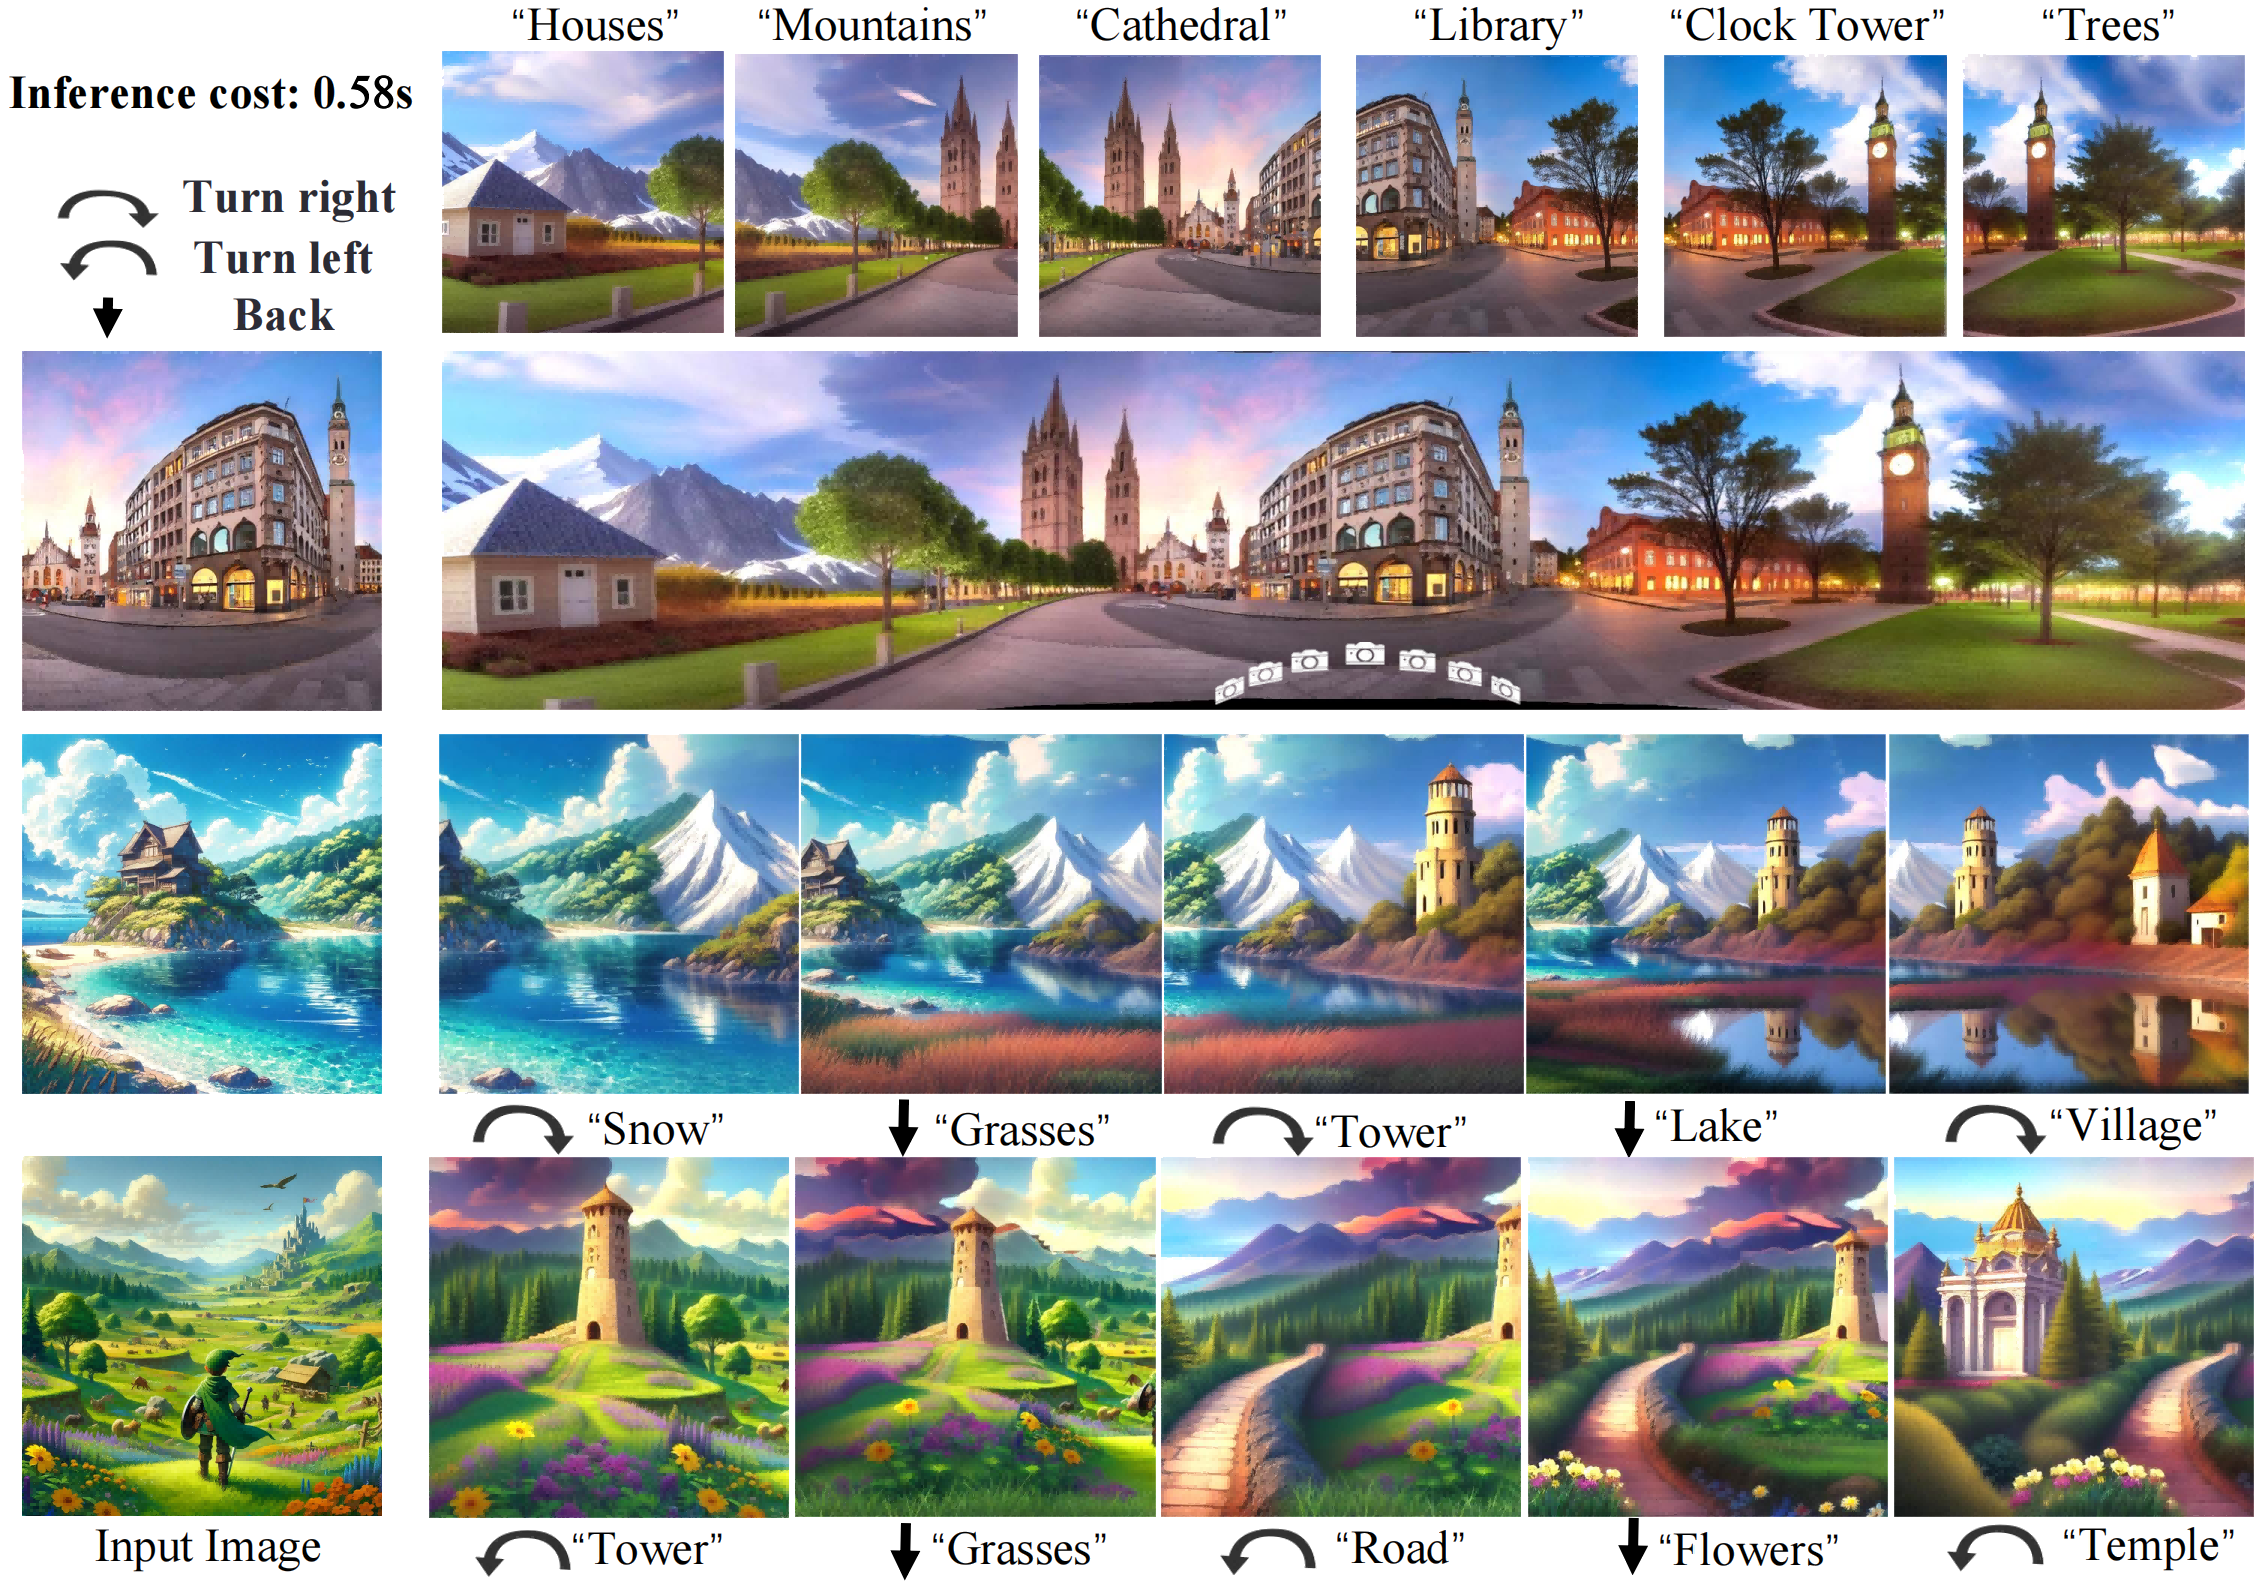
Generating Interactive 3D World in 0.58 Seconds
Chaojun Ni*, Xiaofeng Wang*, Zheng Zhu*, Haoyun Li*, Weijie Wang*, Guosheng Zhao, Jie Li, Wenkang Qin, Guan Huang, Wenjun Mei
[Project]
[Paper]
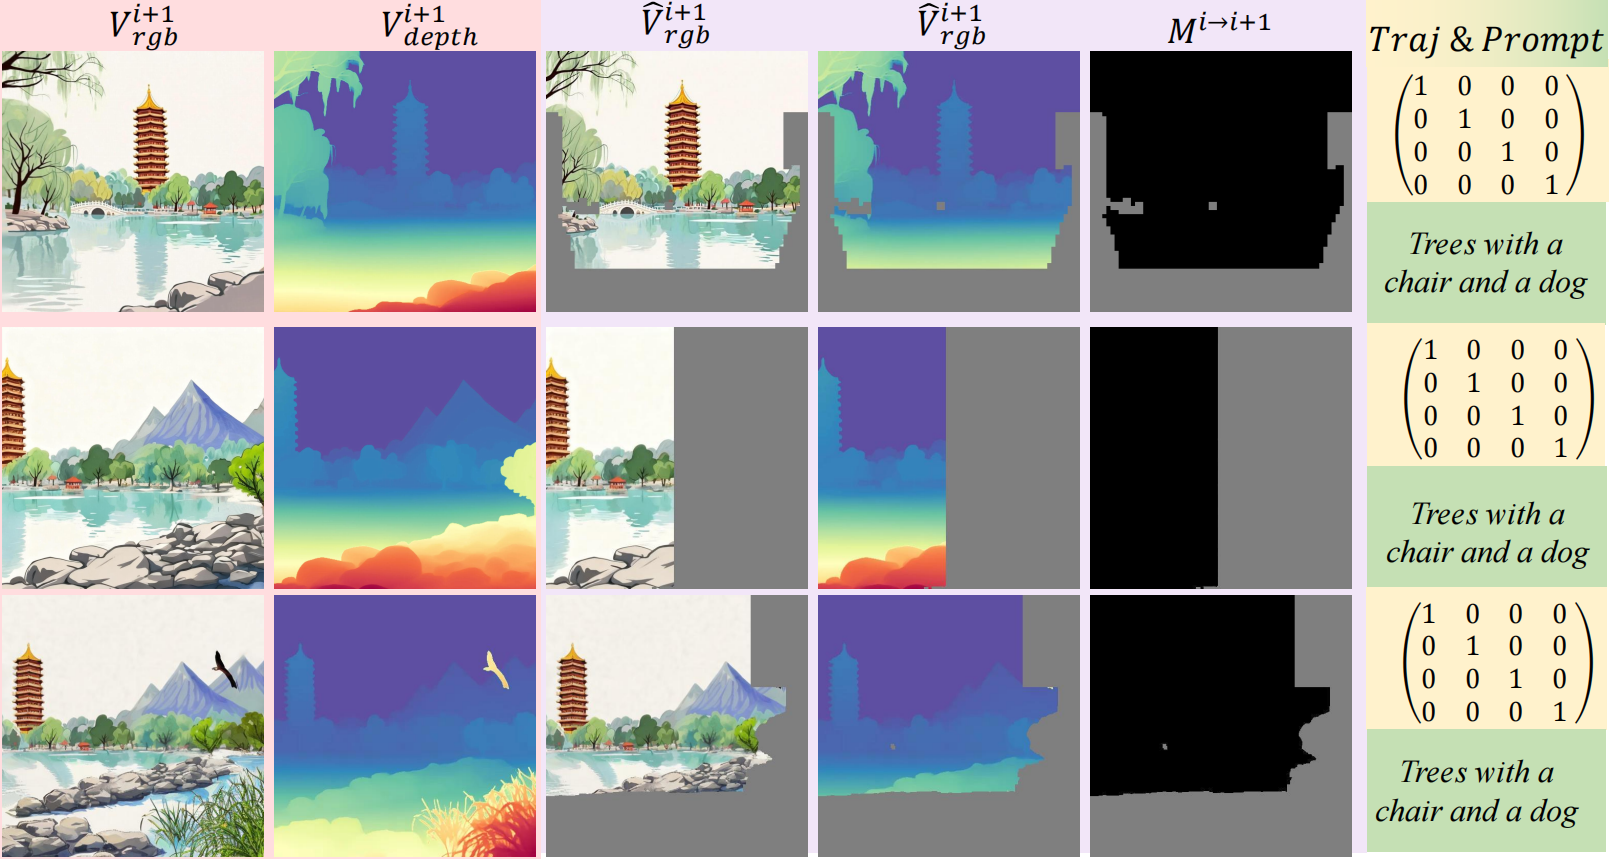
WonderTurbo++ is the first real-time interactive 3D world generation framework capable of generating novel perspectives of 3D scenes within 0.58 seconds, achieving up to 20× speedup over baseline methods while maintaining spatial consistency and high-quality outputs.
|
ECCV 2026
|
GigaWorld-Policy:
An Efficient Action-Centered World–Action Model
Chaojun Ni, Xinyu Zhou, Yukun Zhou, Jingyu Liu, Xiaofeng Wang, Zheng Zhu, Yang Wang, Qiuping Deng, Yun Ye, Hao Li, Zhichao Liu, Jindi Lv, Boyuan Wang, Guosheng Zhao, Guan Huang, Min Cao, Wenjun Mei
[Project]
[Paper]
GigaWorld-Policy is an action-centered World–Action Model (WAM) that learns 2D pixel–action
dynamics with optional video generation. It runs 9× faster than the leading WAM
baseline Motus, improves task success rates by 7%, and outperforms
π0.5 by 95% on RoboTwin 2.0.
|
|
🏆 Awards & Honors
- "Tongzhi Star" Award, 1st Young Scholars Forum on Artificial General Intelligence, 2025 [News]
- Top Ten Graduation Thesis, Jiangxi University of Finance and Economics, June 2024
- ACM-ICPC National Invitational, Silver Medal, April 2021
- ACM-ICPC Asia Regional Contest, Bronze Medal, August 2021
- Alumni Scholarship, Jiangxi University of Finance and Economics, September 2022
|
|